I am Head of AI at a stealth-mode startup and a final-year PhD candidate at the Oxford Robotics Institute, University of Oxford. My thesis is on applying diffusion models to robotic control. Previously I was a machine learning engineer at Kinisi Robotics, did freelance full-stack development, and read Engineering Science at Oxford. I am currently trying to improve my handstands and my chess rating.
News
- Sep 2026: Released DetAug and DistAL on arXiv
- Sep 2026: Started as Head of AI at a stealth startup
- Jul 2025: Joined Kinisi Robotics as a machine learning engineer
- May 2025: Released Flow Planner on arXiv
- Jan 2025: LocoDiff accepted to ICRA 2025
Publications
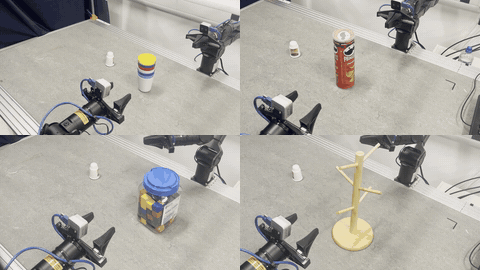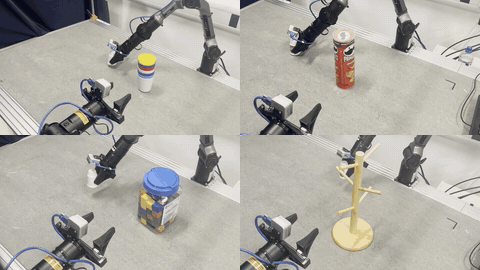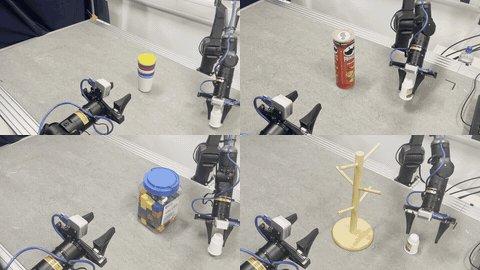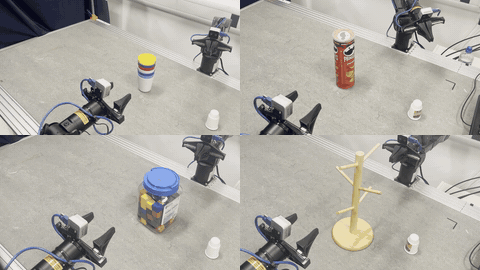 DetAug: Obstacle-Blind Trajectory Augmentation for Zero-shot Obstacle Avoidance · arXiv preprint, 2026
Reece O'Mahoney, Moritz Zoellner, Ioannis Havoutis
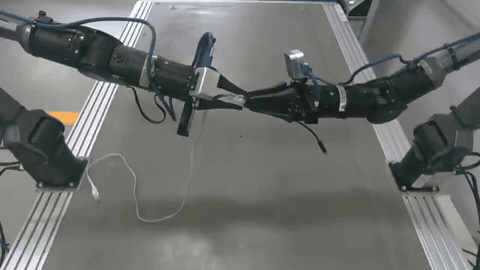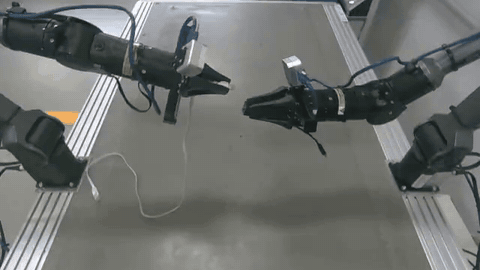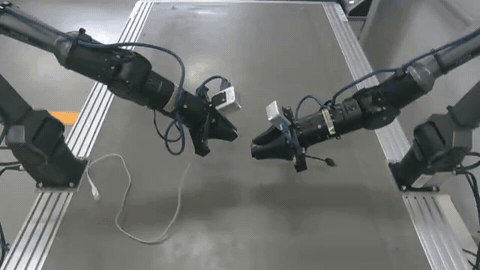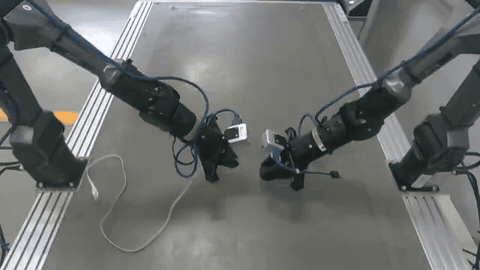 DistAL: Distance-based Advantage Learning for VLA Fine-Tuning · arXiv preprint, 2026
Reece O'Mahoney, Ioannis Havoutis
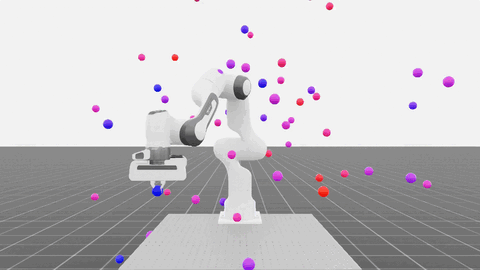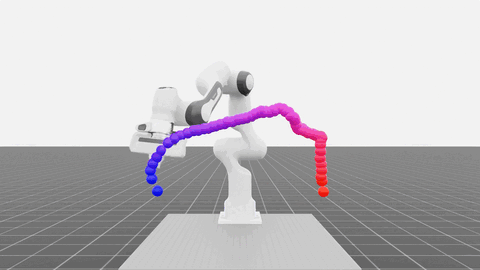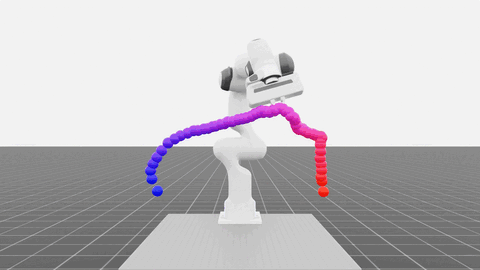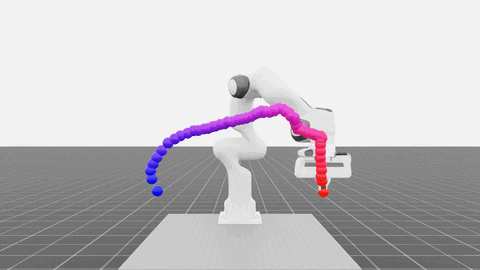 Improving Trajectory Stitching with Flow Models · arXiv preprint, 2025
Reece O'Mahoney, Wanming Yu, Ioannis Havoutis
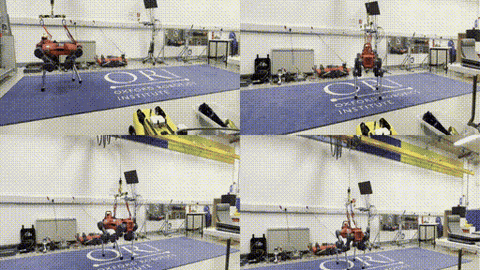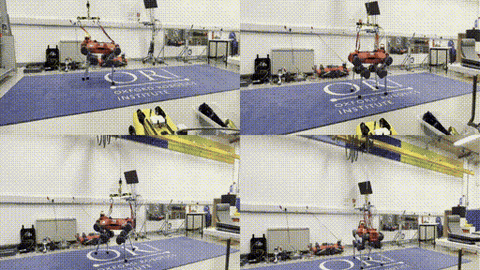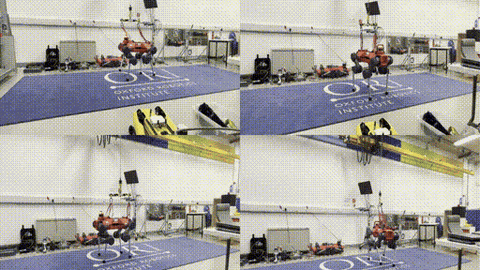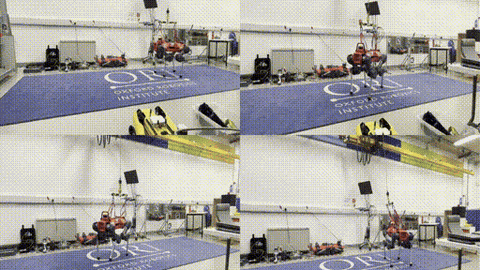 Offline Adaptation of Quadruped Locomotion using Diffusion Models · ICRA 2025
Reece O'Mahoney, Alexander L. Mitchell, Wanming Yu, Ingmar Posner, Ioannis Havoutis
Projects
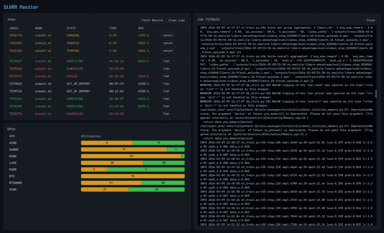 SLURM Tools
CLI for submitting SLURM jobs over SSH and a web GUI for monitoring them across clusters
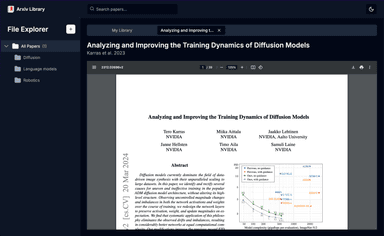 Arxiv Library
A web app for reading and organizing arXiv papers
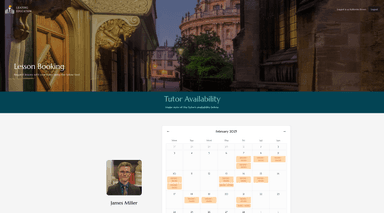 Booking System | Leading Education
Platform for booking and managing client bookings built for a private tuition company